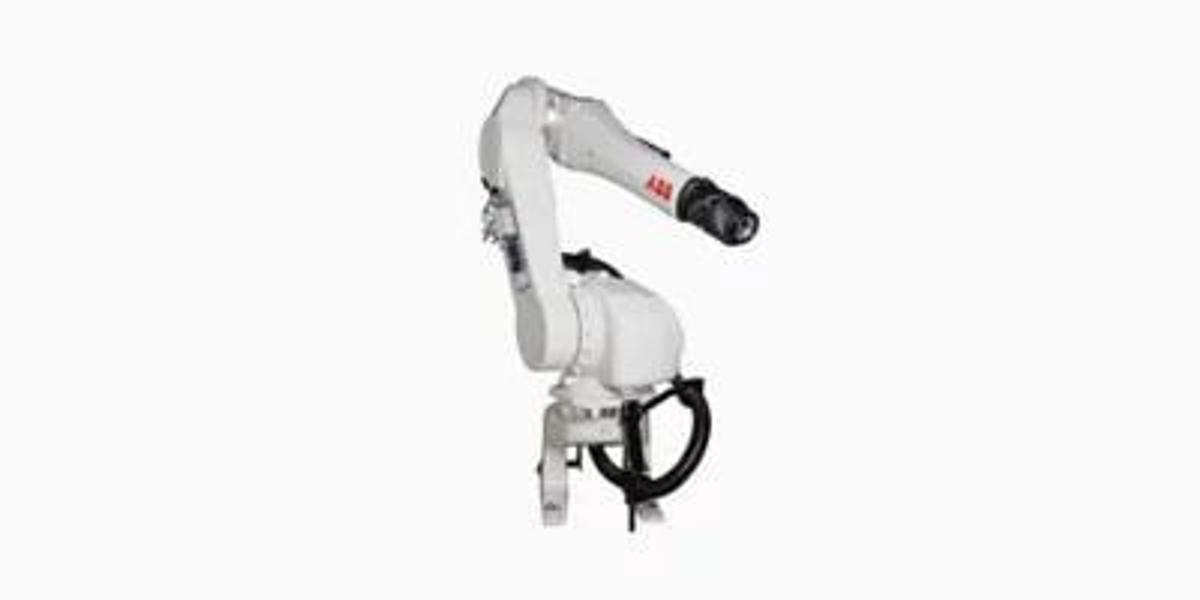
IRB 5510
Description
Small footprint: IRB 5510 offers the same advanced functions as IRB 5500 in a small form factor with a small foot print compared with other similar robots on the market.
Highly versatile: The IRB 5510 is aimed at small work piece painting, flaming treatment, and opener applications.
Shorter cycle times: This robot also provides a shorter cycle time, process optimization, and path control to ensure premium paint quality.
High precision: High-precision technologies including ABB’s hollow wrist, IPS, and bell technologies
Increased productivity: Increased productivity with rapid installation and high system uptime
Specifications
| Manufacturer | ABB |
| Model | IRB 5510 |
| Condition | New |
| Payload on wrist | 13 kg |
| Protection | IP66 IP |
| Protection on wrist | IP54 IP |
Documents
- download-aspx-documentid-9akk107992a0209-languagecode-en-documentpartid-action-launch
- download-aspx-documentid-9akk108472a4375-languagecode-en-documentpartid-action-launch
- download-aspx-documentid-9akk107992a1614-languagecode-en-documentpartid-action-launch
- download-aspx-documentid-9akk107992a1615-languagecode-en-documentpartid-action-launch
- download-aspx-documentid-9akk107992a1616-languagecode-en-documentpartid-action-launch
- download-aspx-documentid-9akk107046a5155-languagecode-en-documentpartid-action-launch
- download-aspx-documentid-9akk107046a5156-languagecode-en-documentpartid-action-launch
- download-aspx-documentid-9akk107046a5157-languagecode-en-documentpartid-action-launch
- download-aspx-documentid-9akk107046a5158-languagecode-en-documentpartid-action-launch
- download-aspx-documentid-9akk107046a5160-languagecode-en-documentpartid-action-launch
- download-aspx-documentid-9akk107046a5159-languagecode-en-documentpartid-action-launch
- download-aspx-documentid-9akk108468a6095-languagecode-en-documentpartid-action-launch
- download-aspx-documentid-9akk107046a7462-languagecode-en-documentpartid-action-launch
- download-aspx-documentid-9akk107046a7471-languagecode-en-documentpartid-action-launch